

Wuxi Foken Cutting & Welding Equipment Co., Ltd.
Tel: 13812090222
13812096242
Fax: 0510-83291211
E-mail: manager@volcanocn.com
Address: No.25 Tianshun Road, Yangshan Town, Huishan District, Wuxi City, Jiangsu Province, China
How to Improve the Positioning Accuracy of Welding Manipulators via Servo Motor Drive
How to Improve the Positioning Accuracy of Welding Manipulators Using Servo Motor Drives
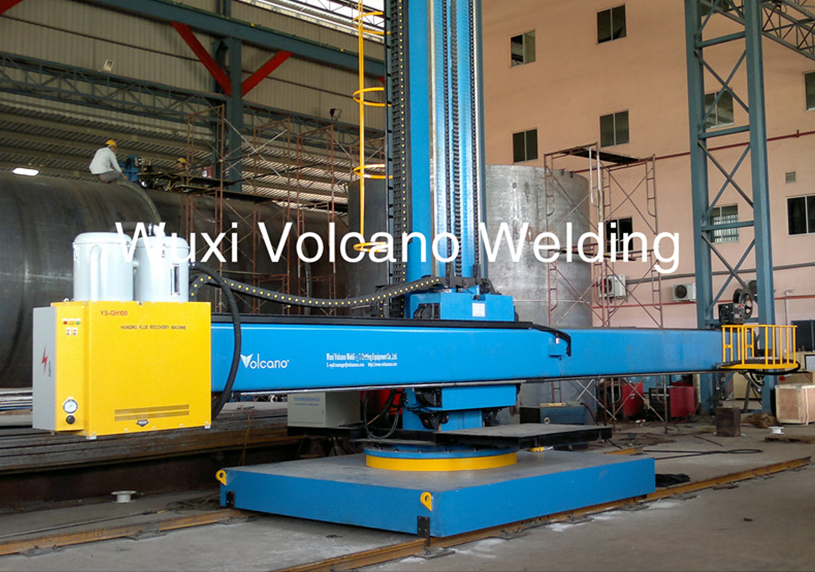
Today, Wuxi Fukan Welding & Cutting Equipment Co., Ltd., a manufacturer of welding manipulators, will introduce relevant content about welding manipulators.
To improve positioning accuracy through servo motor drives in welding manipulators, comprehensive strategies are adopted in four dimensions: hardware selection, control algorithm optimization, mechanical system design, and environmental adaptability. The specific solutions are as follows:
I. Hardware Selection: High-Precision Core Components Lay the Foundation
Matching Servo Motors and Drives
Permanent Magnet Synchronous Motors (PMSM) are selected as the drive core of welding manipulators, featuring high power density and low inertia for fast response.
For example, after adopting PMSM, a brand of 6-axis robot achieves a repeat positioning accuracy of ±0.02 mm.
The drive supports EtherCAT bus technology, realizing nanosecond-level synchronization accuracy and ensuring position deviation within ±1 μm during multi-axis cooperative control.
Upgrading Encoder Resolution
Absolute encoders are used instead of incremental encoders to directly output rotor position information and eliminate cumulative errors.
For instance, a 23-bit absolute encoder provides up to 8.38 million pulses per revolution, enabling positioning error below 0.001 mm in complex trajectory welding.
II. Control Algorithm Optimization: Dynamic Compensation for Faster Response
Three-Step PID Tuning Method
P adjustment: Set I and D to zero, gradually increase P until mild oscillation occurs, then use 80% of this value.
I adjustment: Keep P fixed, increase I gradually, and select parameters with no overshoot and short stabilization time.
D adjustment: Keep P and I fixed, increase D until position overshoot is minimized.
In an injection molding machine injection table positioning project, this method improved accuracy from ±0.1 mm to ±0.01 mm and reduced stabilization time from 2 seconds to 0.8 seconds.
Integration of Feedforward Control and Adaptive Algorithms
Feedforward control is added to the PID closed-loop to pre-compensate dynamic system errors.
During high-speed welding, feedforward control adjusts motor output in advance to reduce trajectory tracking delay.
Meanwhile, adaptive algorithms adjust parameters in real time according to load changes, maintaining positioning accuracy during thick-plate welding.
III. Mechanical System Design: Rigid Structure Reduces Error Accumulation
Optimized Transmission System
Backlash-free harmonic gears or planetary gears replace traditional gears to eliminate mechanical backlash.
A welding equipment manufacturer reduced transmission error from ±0.5 mm to ±0.1 mm by using harmonic gears.
Enhanced System Rigidity
The beam and column structure is optimized with high-strength materials (such as carbon fiber composite) to improve rigidity and prevent deformation under load.
For wind tower welding with a 12-meter turning radius, finite element analysis optimizes the base structure to avoid positioning deviation caused by vibration.
IV. Environmental Adaptability: Anti-Interference Design Ensures Stability
Temperature Compensation Mechanism
Temperature sensors are installed at key positions to monitor dimensional changes caused by thermal expansion and contraction.
In nuclear power thick-plate welding, temperature compensation reduced positioning error from ±0.2 mm to ±0.05 mm.
Electromagnetic Interference Shielding
Shielded cables and optimized grounding reduce EMI from welding arcs to the servo control system.
In ship panel assembly welding, the manipulator uses magnetic guide rails for curved-surface welding while ensuring stable encoder signals to avoid positioning jumps caused by interference.
Name*
*Email
Phone
Message
*